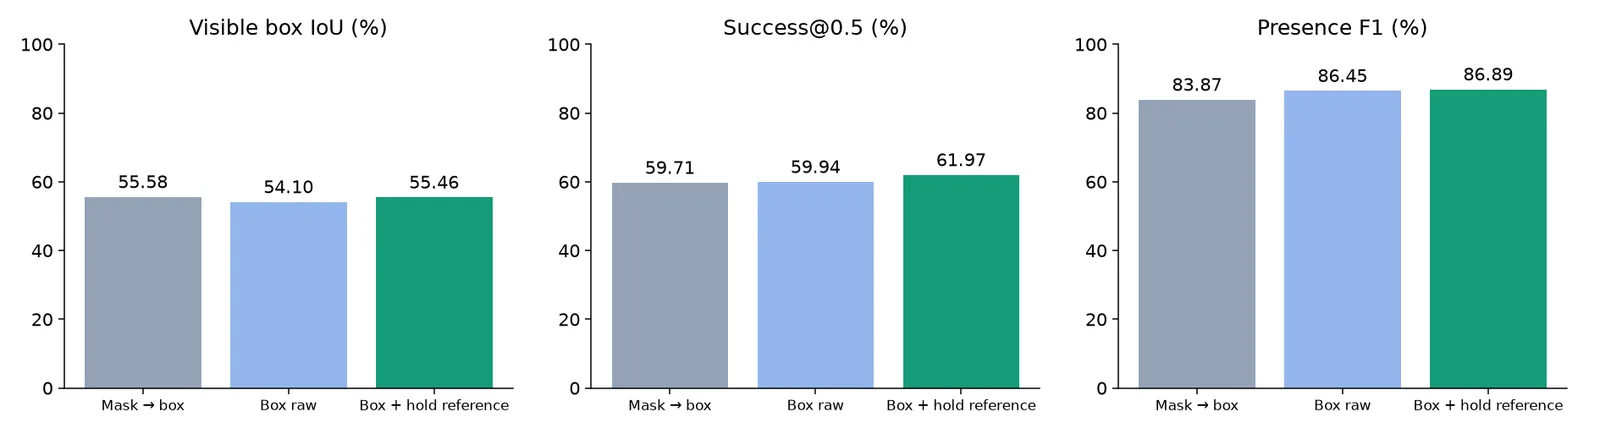
Stage 1 delivers a 2D multi-object box tracker with recurrent box memory. The selected inference policy preserves the last valid reference when an object is absent.
All 32 original comparison videos are restored here. These are early-checkpoint demonstrations, not videos of the final phase-30 + hold-reference checkpoint.
| Component | Mask teacher | Selected box student |
|---|
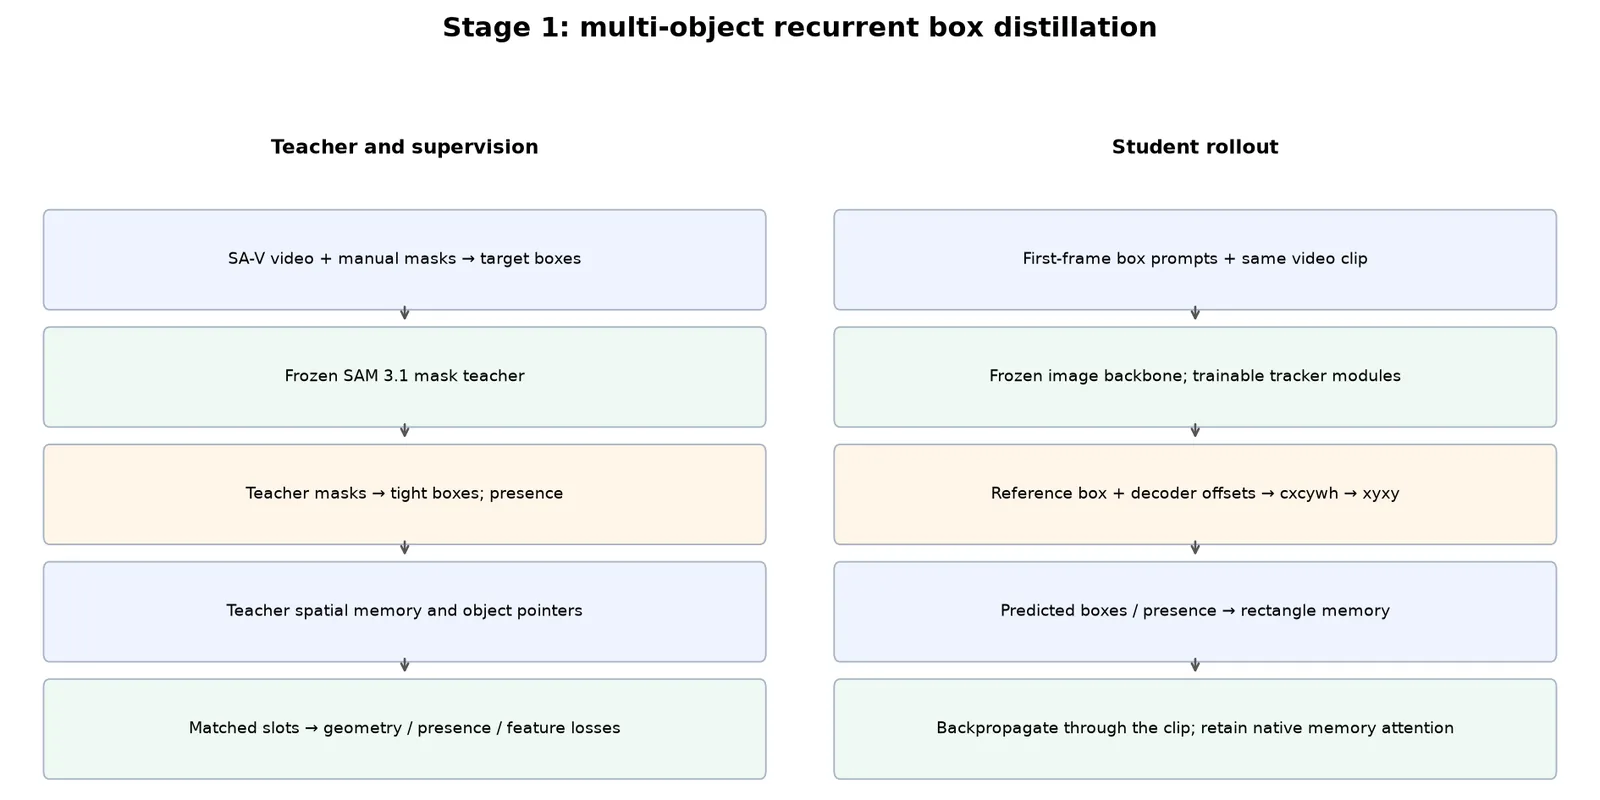
| Object output | Segmentation mask | Detector-reference 2D box and presence |
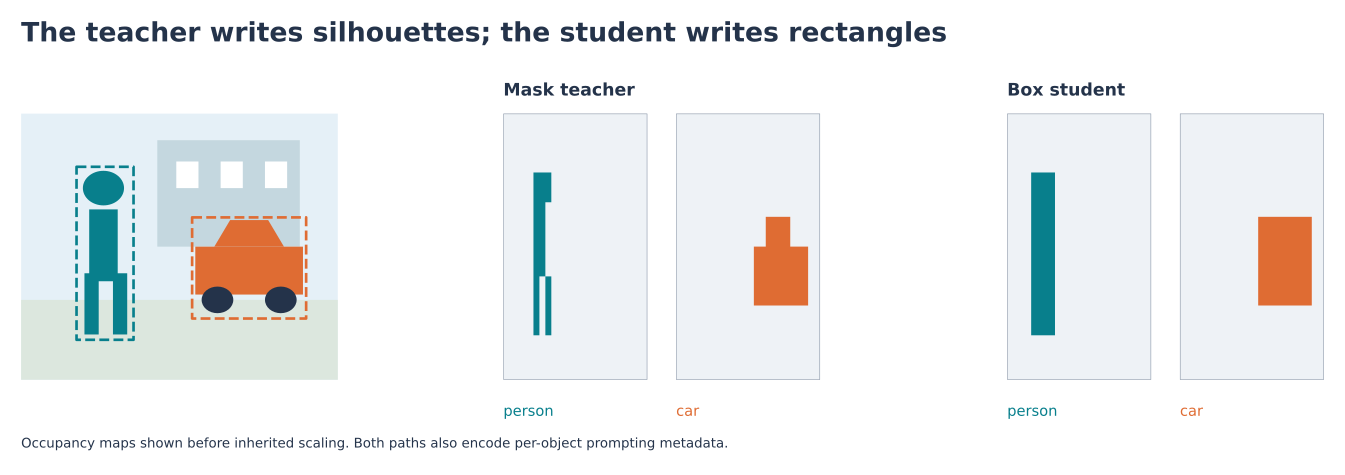
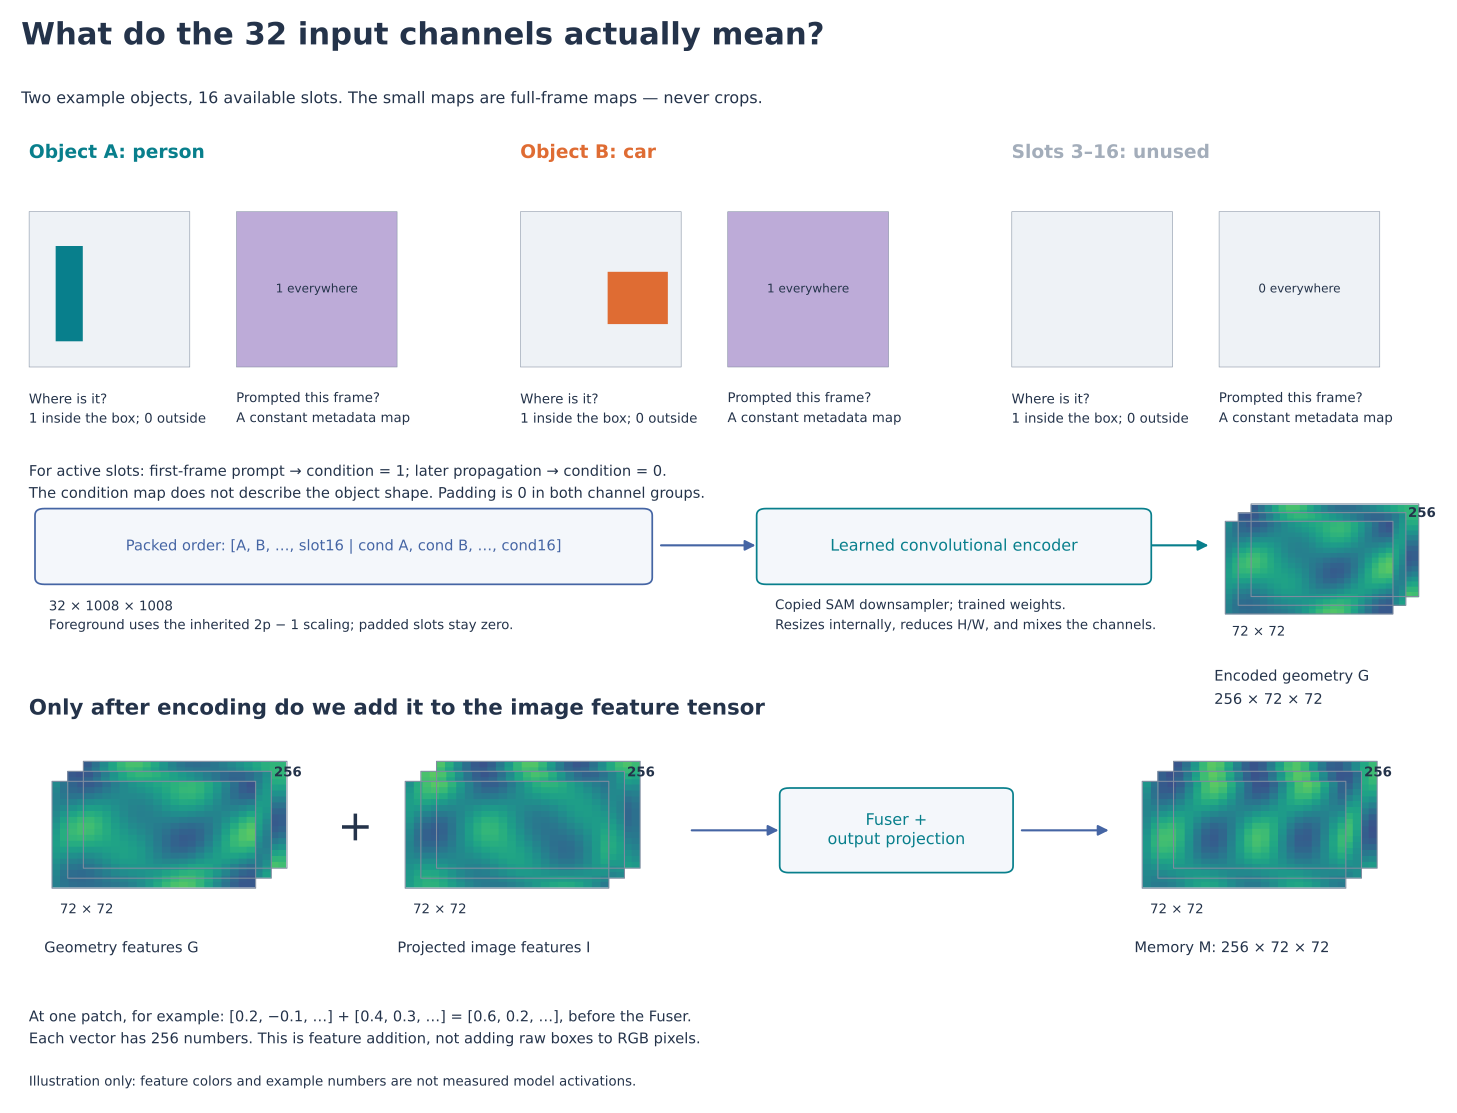
| Memory geometry | Mask probability | Differentiable rectangle occupancy, gated by presence |
| Encoder weights | Official SAM modules | Initialized from the teacher; trained downsampler, image projection, Fuser and output projection |
| Fusion | Projected image features + encoded geometry | Same additive fusion, followed by Fuser |
| Background | Spatial feature map with object conditioning | Full spatial feature grid remains; outside-box features are not forcibly zeroed |
| Multi-object state | Multiplex object slots and pointers | Same mechanism; 16 slots per bucket, additional buckets for more objects |